Linear variable differential transformers (LVDT) are an electromechanical transducers that senses the mechanical displacement of a core and produces a proportional AC voltage at the output. This article by Steve Arar explain LVDT basics, including structure, circuit, transfer function, linear range, sensitivity, and more.
A linear variable differential transformer converts axial core displacement into an electrical position signal using magnetic coupling between windings. This guide explains LVDT basics for design and component engineers, covering construction, operating principles, transfer function, linear range, sensitivity, signal conditioning and practical selection.
Key Takeaways
An LVDT is a position-measurement transformer, not a power-conversion transformer. Its useful performance depends on the sensor, mechanical installation and conditioning electronics working together.
- A conventional AC LVDT contains one primary winding, two secondary windings and a movable magnetically permeable core. The differential secondary signal indicates displacement from an electrical null. [1]
- Output amplitude indicates distance from null; phase-sensitive detection distinguishes the two sides of null. Real sensors can require compensation for primary-to-secondary phase shift. [1, 3]
- Specified linearity applies only over the rated linear range and under stated excitation and loading conditions. One-sided full-scale displacement and end-to-end full range are not interchangeable. [2, 4]
- The free-core sensing interface can operate without contact, but guided probes, bearings and mechanical linkages introduce their own constraints. Practical resolution is limited by the complete measurement system. [1, 2]
- Sensitivity is normally normalized to excitation voltage and displacement. Compare it at the specified excitation frequency, and include phase, noise, bandwidth and environmental requirements when selecting the conditioner. [2, 3]
LVDT Basics: Structure and Operating Principle
An LVDT measures displacement by changing the magnetic coupling between a primary winding and two secondary windings. The discussion below concerns the conventional differential AC LVDT; sensors with integrated electronics use the same underlying sensing principle but provide a conditioned output. [1]
Structure of an LVDT
Figure 1 shows a cutaway view of the sensor, and Figure 2 shows its circuit model. A movable magnetically permeable core links the primary winding to the secondary windings. As the core moves, the coupling to each secondary changes, producing position-dependent secondary voltages. [1]

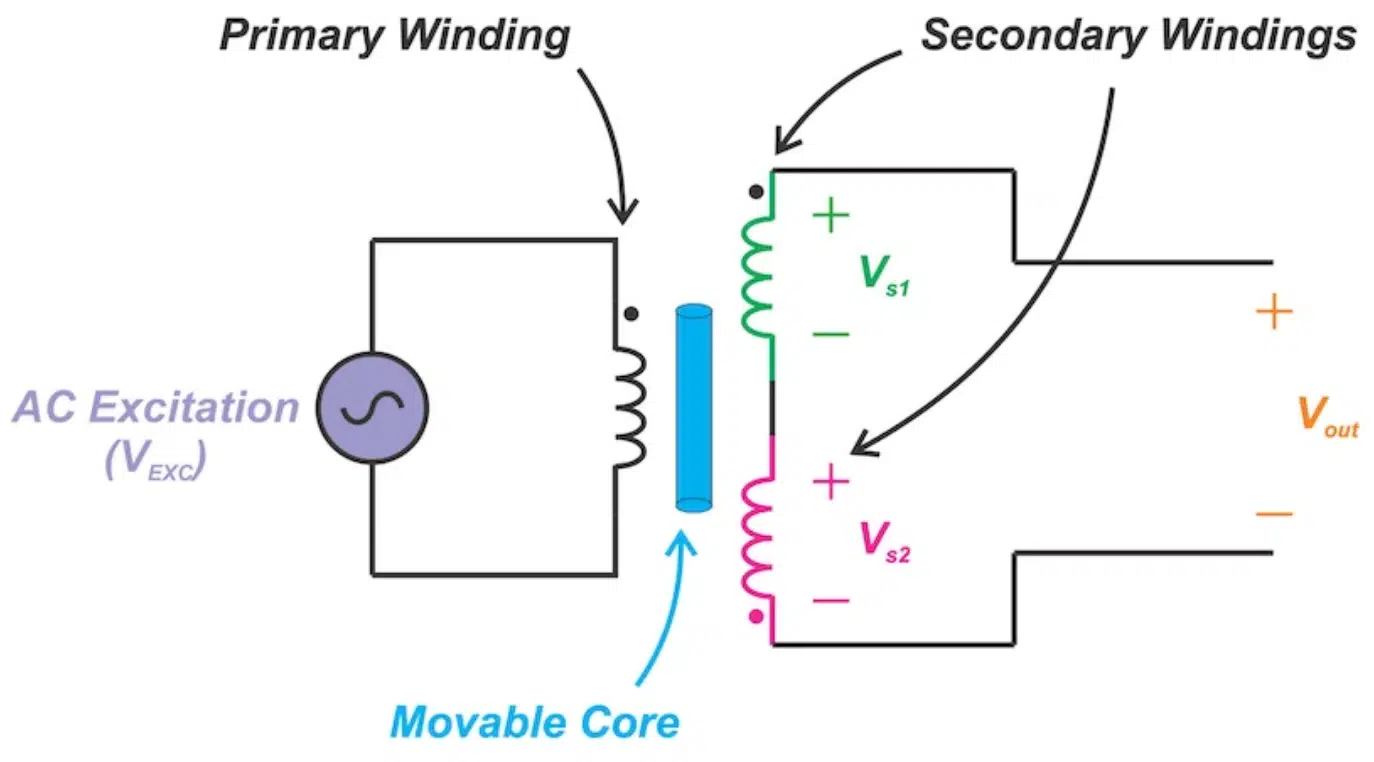
The secondaries are connected in series opposition so that their induced voltages subtract at the output terminals. This describes the electrical polarity of the connection; it does not require an assumption that the two coils were physically wound in opposite directions. Follow the supplier’s winding diagram and terminal identification. [1, 4]
The core is usually attached to the measured object through a connecting rod, while the coil assembly is fixed to a reference structure. In a free-core arrangement, clearance allows the core to move without touching the bore. Guided and spring-loaded gauging probes add mechanical guidance and contact forces, so frictionless sensing should not be confused with an entirely frictionless measurement assembly. [1]
An ideal magnetic displacement transducer has no discrete position steps. In practice, usable resolution depends on electrical noise, output ripple, bandwidth, conversion electronics and mechanical stability; it is not an unlimited system specification. [2, 3]
How does it work?
The primary is energized by an AC excitation voltage, VEXC, at the amplitude and frequency specified for the sensor. For a consistent sign convention, let Vs1 and Vs2 represent secondary-voltage phasors measured with matching winding-polarity references, and let Vout be the series-opposed differential output. Eq. (1) then defines the output. [1]
At the ideal centered position, the coupling to both secondaries is equal. Their voltages cancel in the differential connection, giving zero output. This electrical reference position is called null, as illustrated in Figure 3. [1]

When the core moves upward in Figure 4, coupling to the first secondary increases relative to the second, so |Vs1| > |Vs2|. The differential output is non-zero and has the polarity associated with the first secondary under the selected terminal convention. [1]
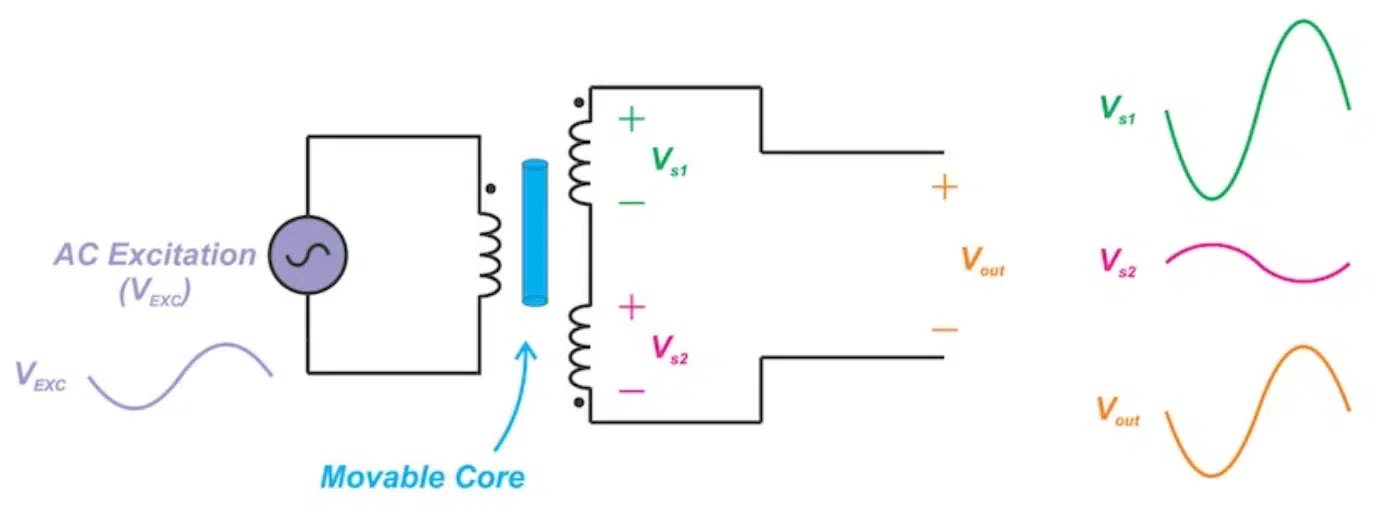
When the core moves downward in Figure 5, the second secondary becomes dominant and |Vs2| > |Vs1|. For equal displacement on opposite sides of null, the ideal differential outputs have equal amplitude and opposite phase. [1]
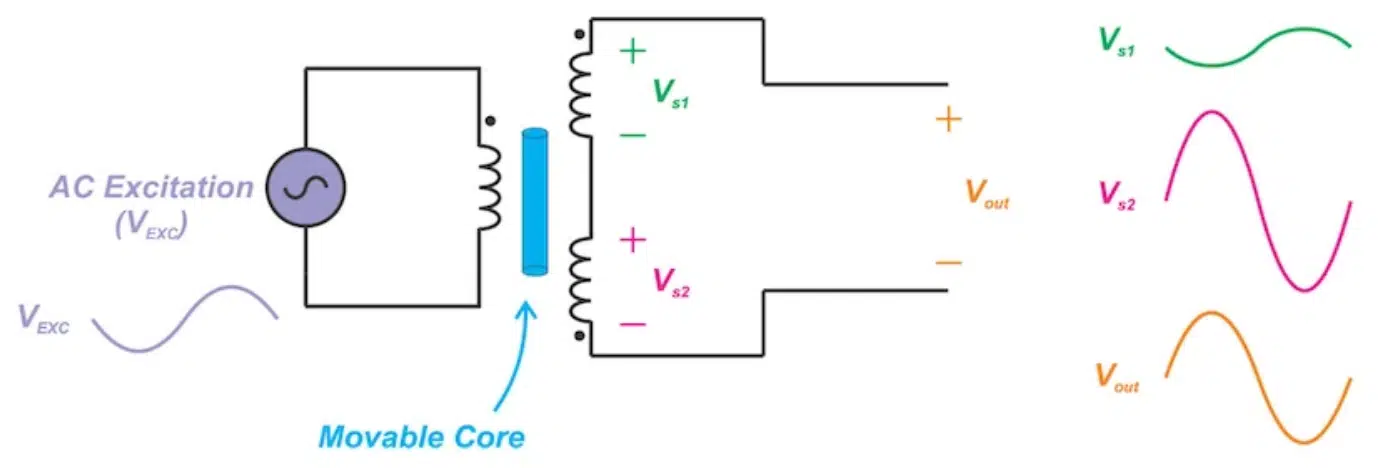
The idealized drawings associate one direction with an output in phase with the excitation and the other with an output 180° out of phase. A real LVDT can introduce an additional primary-to-secondary phase shift. The practical requirement is therefore to establish the correct reference phase and output polarity, rather than assume exact alignment with the primary excitation. [1, 3]
Transfer Function and Linear Range
The transfer function relates displacement to electrical output under defined operating conditions. Distinguishing unsigned AC amplitude from signed position is essential when interpreting a graph or selecting a readout circuit. [1, 2]
Transfer function
Figure 6 illustrates the relationship between core displacement from center and output AC amplitude. At the ideal origin, displacement x is zero and the differential output is zero. Within the linear range, output amplitude increases approximately in proportion to distance from null. [1, 6]
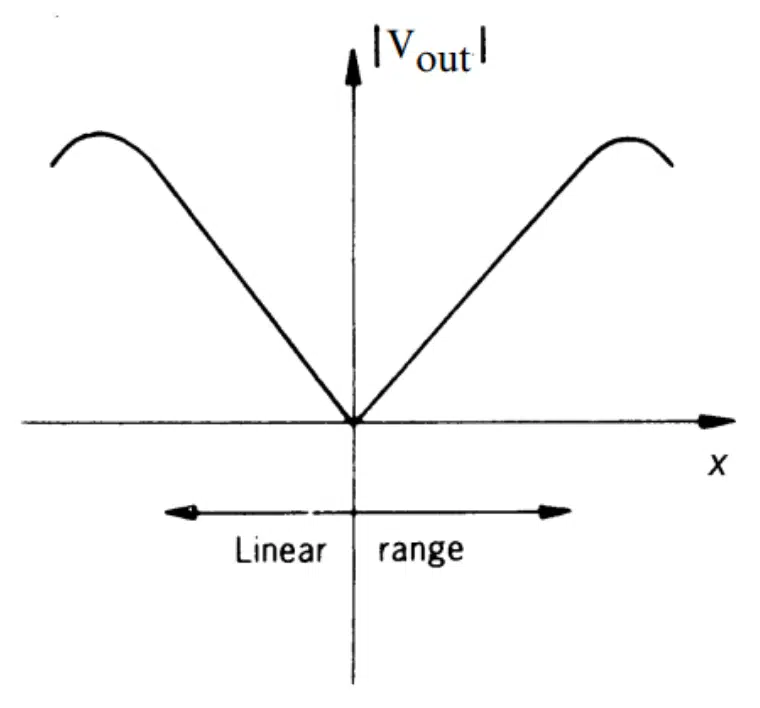
Amplitude alone cannot distinguish equal displacements on opposite sides of null. A phase-sensitive conditioner converts the AC signal into a signed position output, preserving both distance and direction relative to the reference position. [1, 3]
Linear range
The specified linear range is the interval over which the sensor meets its stated non-linearity limit. Beyond this interval, the geometry-dependent changes in coupling no longer maintain the same proportional relationship. The sensor may continue producing an output outside the rated range, but that output must not be assumed to retain the specified linearity. [1, 2]
Full-scale displacement is the maximum specified travel from null toward one end. Full range, full stroke or total stroke is the end-to-end distance. Thus, a nominal linear range written as ±xFS corresponds to a total stroke of 2xFS, where xFS is the one-sided full-scale displacement. [2]
These definitions matter when comparing catalog parts. For example, the TE Connectivity E series covers nominal strokes from ±2.54 mm to ±50.8 mm; the E-100 has ±2.54 mm travel and therefore a 5.08 mm total stroke. Other constructions serve laboratory, industrial, actuator and subsea applications, but measuring range and environmental suitability must be checked for the specific model. [1, 4]
Nominal linear range and sensitivity depend on excitation frequency, while output loading can affect linearity and usable range. Compare specifications only when the excitation, load and measurement definitions are compatible. [2]
Linearity Error and Practical Null Behavior
A real LVDT does not follow a perfect straight line, even within its rated range. Static non-linearity, residual voltage at null and electronic noise describe different limitations and should be evaluated separately. [2, 3, 4]
Linearity error
Linearity error is the maximum deviation of the measured output from a defined reference straight line over the specified range. A best-fit line is common, but the supplier’s definition governs the comparison. Record both the reference-line method and the denominator used for the percentage specification. [2]
The E-100 specifies maximum non-linearity of ±0.5% of full range. Its datasheet defines full range as the end-to-end stroke and full-range output as the algebraic difference between the outputs at the two stroke ends. This must not be interpreted as ±0.5% of the one-sided 2.54 mm displacement. [4]
Non-linearity is not the same as total measurement uncertainty. The complete system also depends on excitation conditions, phase alignment, loading, conditioning electronics and mechanical installation. A calibration should therefore assess the assembled measurement chain, not just rely on the sensor’s headline linearity figure. [1, 2, 3]
Null residual, distortion and filtering
Zero AC output at null is an idealization. Real sensors specify a residual null voltage; for example, the E-series datasheet gives a maximum null voltage of 1% of full-range output. A broadband RMS reading near null can therefore remain non-zero even when the calibrated signed position output is at its reference point. [3, 4]
Magnetic saturation and excessive excitation can distort the signal, so the specified drive conditions should be respected. Waveform distortion, however, must not be treated as interchangeable with position-dependent static non-linearity. [1, 3]
Filtering after demodulation reduces carrier-related ripple and noise, but it also limits response speed and adds phase lag. It does not generally remove static deviations of position output from the reference straight line. Use appropriate excitation, phase alignment, installation and calibration to address those errors. [2, 3]
Sensitivity and the E-100 Example
Sensitivity relates differential output voltage to displacement after normalizing for primary excitation. It determines the required electrical gain, but does not by itself establish resolution, accuracy or bandwidth. [2, 3]
Sensitivity definition and measurement
Let S be normalized sensitivity, Vout,rms the differential output RMS amplitude, VEXC,rms the primary excitation RMS voltage and |x| the non-zero displacement magnitude from null. The ideal proportional relationship gives Eq. (2). Use compatible voltage conventions and the sensor’s specified excitation frequency. [3, 7]
To measure sensitivity, energize the primary at the recommended drive level, move the core to a known position within the linear range and measure the differential secondary output. A full-scale measurement gives a useful first estimate; measurements at several known positions are needed to distinguish slope, offset and non-linearity. [2, 3]
Sensitivity is often specified in mV/V/mm or in the legacy unit mV/V/mil. One mil is 0.001 inch, equal to 25.4 µm. Keep displacement units consistent throughout the calculation. Sensitivity should not be confused with the dimensionless voltage transformation ratio at a particular position. [3, 4]
Worked example: endpoint output and full-range error
The E-100 has nominal sensitivity of 2.4 mV/V/mil, equivalent to approximately 94.49 mV/V/mm; the datasheet rounds this to 94.5 mV/V/mm. Its rated stroke is ±2.54 mm, or ±100 mil, with 3 V RMS sinusoidal excitation. The electrical specifications are characterized at 2.5 kHz. [4]
Let rFS be the dimensionless differential-output-to-excitation ratio at one stroke end. Using the original sensitivity and full-scale displacement gives Eq. (3).
At 3 V RMS excitation, the nominal endpoint differential amplitude is therefore 0.72 V RMS, as calculated in Eq. (4). This agrees with the datasheet’s endpoint ratio of 240 mV/V. [3, 4]
The two stroke ends have opposite phase. Expressed as a signed, phase-referenced RMS-equivalent output, they are nominally −0.72 V and +0.72 V, giving a 1.44 V algebraic end-to-end span. An ordinary unsigned RMS meter does not display that signed span.
The displacement equivalent of ±0.5% full-range non-linearity is obtained from the 5.08 mm total stroke. Let ex,max denote that equivalent maximum displacement deviation. Eq. (5) gives ±25.4 µm; this is a non-linearity contribution, not a complete system accuracy specification. [4]
These calculations establish the nominal signal presented to the conditioner. Select gain and offset to map the signed sensor range into the required readout range, while retaining headroom for residual offset, tolerances and operating-condition changes. [3]
Signal Conditioning and Measurement Practice
A bare AC LVDT needs excitation, differential signal processing and phase-sensitive conversion to produce a convenient position output. The conditioner is part of the measurement system and can determine its practical noise, response speed and drift. [1, 3]
Phase-sensitive and ratiometric detection
A synchronous demodulator uses a reference related to the excitation to recover signed displacement. The reference must remain usable through null, where the differential secondary signal becomes very small. Sensor phase shift may require a lead or lag compensation network. The E-100 specifies a nominal phase shift of −3° at its stated test frequency. [3, 4]
Ratiometric conditioning measures the secondary signal relative to primary excitation, reducing scale-factor error caused by excitation-amplitude drift. The AD698 is one implementation: it synchronously detects primary and secondary signals and forms their ratio. This does not eliminate sensor non-linearity or every other source of measurement error. [3]
A DC-operated LVDT includes the AC excitation and conditioning electronics within the assembly. It simplifies the external interface, but its electronics, supply requirements, output scaling and environmental ratings must be evaluated as part of the sensor specification. [1]
Bandwidth, noise, loading and cabling
Excitation frequency is not the same as mechanical measurement bandwidth. Demodulation and output filters must pass the required motion signal while suppressing carrier ripple and noise. Increasing filter capacitance can reduce ripple but also slow the response and increase phase lag, which matters in closed-loop position control. [3, 5]
Use a secondary-input impedance compatible with the sensor specification. Low loading impedance can change the transfer characteristic and usable linear range. Validate the assembled system with its intended cable and grounding arrangement, because wiring can introduce interference and affect the electrical conditions seen by the conditioner. [1, 2]
When several LVDTs operate close together, stray magnetic coupling between independently excited sensors can produce beat interference. Synchronized excitation is an established approach to avoiding this problem; each driver must still meet its electrical and thermal loading limits. [5]
Design and Selection Checklist
Start selection from the required motion, uncertainty budget and installation environment rather than sensitivity alone. Compare catalog specifications under matching conditions, and validate the complete sensor, cable and conditioner assembly before release. [1, 2, 3]
- Measuring range: specify required travel from null, total stroke, rated linear range and permissible mechanical movement. Do not assume that electrical linear range is a mechanical stop. [1, 2]
- Electrical conditions: compare excitation waveform, RMS voltage, frequency, primary impedance, secondary loading, sensitivity, phase shift and null voltage. Check driver capability and conditioner input headroom. [3, 4]
- Error definitions: record the non-linearity reference line, full-range denominator, repeatability, temperature behavior and calibration conditions. Keep resolution, repeatability and accuracy as separate requirements. [2]
- Dynamics: define required measurement bandwidth, settling behavior, allowable ripple and control-loop phase lag. Select filtering for the real motion signal rather than the carrier frequency alone. [3, 5]
- Mechanical installation: choose free-core, guided or spring-loaded construction; verify alignment, coupling, attachment thread, mounting space and probe force where applicable. [1, 4]
- Environment: compare operating temperature, sealing, pressure and fluid compatibility, corrosion resistance, shock, vibration and cable or connector construction. A general industrial LVDT is not automatically suitable for immersion or hydraulic-cylinder installation. [1, 4]
- Catalog versus custom: use a catalog assembly when its stroke, mechanical interface, environment and conditioner compatibility meet the requirements. If a custom configuration is necessary, freeze those interfaces and acceptance criteria in the procurement specification rather than relying on a generic LVDT description.
- Qualification and safety: define application-specific environmental and electrical acceptance tests. For safety-related position feedback, assess the complete sensing and control architecture; the LVDT operating principle alone does not establish a safety qualification.
- Production control: retain the specified core, wiring convention and calibration configuration with the sensor assembly. Confirm output polarity, endpoint response and residual error on representative hardware before approving substitutions. [2, 3]
Conclusion
An LVDT converts displacement into a differential AC signal whose amplitude and phase encode distance and direction from null. Its main strengths arise from magnetic, non-contact sensing, but practical performance depends on the mechanical arrangement and the complete conditioning chain. [1, 3]
For selection and design, establish the rated linear range, distinguish one-sided full-scale travel from end-to-end full range, and compare sensitivity at the specified excitation frequency. Then verify phase alignment, loading, filtering, environmental suitability and calibrated residual error in the installed configuration. [2, 3, 4]
FAQ
An LVDT uses a movable magnetic core to change coupling between a primary winding and two secondary windings. The primary receives AC excitation, while the secondary voltages are connected differentially. Their output amplitude indicates distance from the electrical null, and phase-sensitive detection identifies which side of null the core occupies.
A bare AC LVDT requires external excitation and signal conditioning. A DC-operated LVDT combines the AC sensing element with an internal oscillator and conditioning electronics, providing a convenient conditioned output. Selection must consider the complete assembly, including its supply requirements, output scaling, electronics temperature limits and environmental rating.
Full-scale displacement is the specified travel from null toward one end of the linear range. Full range is the complete end-to-end stroke, equal to twice the one-sided displacement for a symmetric sensor. For example, a sensor rated for ±2.54 mm has a total stroke of 5.08 mm. This distinction affects interpretation of percentage non-linearity specifications.
Normalized sensitivity is differential output RMS voltage divided by primary excitation RMS voltage and known displacement magnitude from null. Use a non-zero position within the rated linear range and the specified excitation frequency. Keep displacement units consistent. Multiple known positions provide a better calibration because they distinguish sensitivity from offset and non-linearity.
Those are idealized descriptions, not complete system specifications. The magnetic sensing principle has no discrete position steps, but practical resolution is limited by noise, ripple, bandwidth, conversion electronics and mechanical stability. Real sensors also have residual null voltage, so an unsigned RMS reading can remain non-zero at the calibrated reference position.
How to Measure LVDT Sensitivity and Check Calibration
Measure normalized sensitivity and assess the complete LVDT measurement chain under defined electrical and mechanical conditions.
- Confirm the sensor specification
Record the rated linear range, excitation voltage and frequency, wiring convention, load requirement and definition of full range. Use the specified core and the intended conditioner and cable.
- Install and excite the sensor
Mount the coil assembly and align the core coupling without unintended contact or side loading. Apply the specified sinusoidal excitation and verify the primary voltage under operating load.
- Establish null and direction
Locate the electrical null using phase-sensitive measurement. Move the core to a known position on each side of null and confirm signed output polarity. Check phase compensation away from null, where the differential signal is sufficiently large.
- Calculate normalized sensitivity
At a known non-zero displacement within the rated range, measure differential output RMS voltage and primary excitation RMS voltage. Divide the output by excitation and displacement magnitude, keeping the displacement units consistent.
- Check the complete range
Record signed output at several known positions across both halves of the stroke. Determine offset and slope using the specified reference-line method, then compare the maximum residual deviation with the allowed non-linearity and its full-range definition.
- Validate the installed measurement chain
Check repeatability, output ripple and required motion response with the final filtering and cable arrangement. Document excitation, loading, temperature, mounting and calibration conditions so that later measurements and substitutions remain comparable.
Further Reading
The following articles provide supporting magnetic-component background. Their power- and signal-transformer examples explain related principles, but their application-specific design rules should not be transferred directly to LVDT position sensors.
- How Transformers and Solenoids Work — background on magnetic coupling and the distinction between transformer action and mechanical actuation.
- Core Magnetic Materials, Permeability and Their Losses — explains permeability, saturation and the influence of material operating conditions.
- Inductor and Transformer Symbols — clarifies winding-polarity marks, magnetic-core symbols and schematic conventions.
- Transformer Calculation, Losses and Leakage Inductance — introduces practical equivalent circuits, loading and parasitic effects in transformers.
References
The operating-principle illustrations and original article structure derive from Steve Arar’s introduction listed in reference [7]. Manufacturer documentation supplies the specification definitions, E-100 example data and conditioning guidance. The retained transfer-characteristic illustration is credited to the textbook in reference [6]. Featured image source: Honeywell.
- TE Connectivity, Understanding LVDTs, TE Connectivity, undated.
- TE Connectivity, LVDT Key Terms, TE Connectivity, undated.
- Analog Devices, AD698: Universal LVDT Signal Conditioner, Rev. D, Analog Devices, 2026.
- TE Connectivity / Measurement Specialties, E Series: Economy Series AC LVDT, Rev. 6, TE Connectivity, 2017.
- Analog Devices, CN-0301: Universal LVDT Signal Conditioning Circuit, Circuits from the Lab, Analog Devices, 2013.
- Ramón Pallás-Areny and John G. Webster, Sensors and Signal Conditioning, Second Edition, Wiley, digital edition listing 2012.
- Steve Arar, Introduction to Linear Variable Differential Transformers (LVDTs), All About Circuits, undated.