Passive Components Blog
No Result
View All Result
  • Home
  • News
    • All
    • Aerospace & Defence
    • Antenna
    • Applications
    • Automotive
    • Capacitors
    • Circuit Protection Devices
    • electro-mechanical news
    • Filters
    • Fuses
    • Inductors
    • Industrial
    • Integrated Passives
    • inter-connect news
    • Market & Supply Chain
    • Market Insights
    • Medical
    • Modelling and Simulation
    • New Materials & Supply
    • New Technologies
    • Non-linear Passives
    • Optoelectronics and Isolation
    • Oscillators
    • Passive Sensors News
    • Resistors
    • RF & Microwave
    • Telecommunication
    • Weekly Digest
    Littelfuse C&K SDE surface-mount DIP switches with gull-wing terminals and top-mounted actuators

    Littelfuse C&K SDE End-Stackable SMT DIP Switches

    Bourns SM91522AL BMS signal transformer with integrated common-mode chokes

    Bourns Releases BMS Transformer with 3.5 mm Height

    DigiKey product distribution center in Thief River Falls, Minnesota

    DigiKey Invests $100 Million to Expand Distribution Capacity

    Conceptual illustration of a Murata NCU01 surface-mount NTC thermistor beside densely arranged electronic components

    Murata World First 008004 NTC Thermistors for Temperature Sensing

    Modelithics COMPLETE+3D v26.4 library for RF passive-component and 3D electromagnetic simulation in Keysight ADS/RFPro

    Modelithics COMPLETE+3D v26.4 Expands RF Models and 3D Workflows

    Wk 42 Electronics Supply Chain Digest

    Siemens executives Markus Grabmeier and Barry Powell with Skeleton Technologies CEO Taavi Madiberk at the investment announcement

    Siemens Backs Skeleton’s US AI Power Manufacturing Expansion

    Concept illustration of an LTCC antenna module with multilayer ceramic substrate, antenna elements and an integrated beamforming IC

    Murata LTCC 6G Antenna Module Demonstrates 135 GHz Operation

    TDK X series surface-mount multilayer varistors with ceramic chip bodies and metal end terminations

    TDK X Series SMD Varistors for Industrial Transient Protection

    Trending Tags

    • Ripple Current
    • RF
    • Leakage Current
    • Tantalum vs Ceramic
    • Snubber
    • Low ESR
    • Feedthrough
    • Derating
    • Dielectric Constant
    • New Products
    • Market Reports
  • Knowledge Blog
  • Dossiers
    • Aerospace and Defense Passive Components Dossier
    • AI Hardware Dossier
    • Automotive Dossier
    • Industrial Robotics Dossier
    • Power Converter Dossier
    • Capacitor Dossier
    • Circuit Protection Dossier
    • Inductor Dossier
    • Resistor Dossier
    • Silicon Capacitors and Integrated Passives Dossier
  • Suppliers
    • Who is Who
  • PCNS
    • PCNS 2025
    • PCNS 2023
    • PCNS 2021
    • PCNS 2019
    • PCNS 2017
  • Events
No Result
View All Result
Passive Components Blog
No Result
View All Result

Magnetic 3-D-printed structures crawl, roll, jump, and play catch

2.7.2018
Reading Time: 4 mins read
A A

Source: MIT news

MIT engineers have created soft, 3-D-printed structures whose movements can be controlled with a wave of a magnet, much like marionettes without the strings.

RelatedPosts

Littelfuse C&K SDE End-Stackable SMT DIP Switches

Bourns Releases BMS Transformer with 3.5 mm Height

DigiKey Invests $100 Million to Expand Distribution Capacity

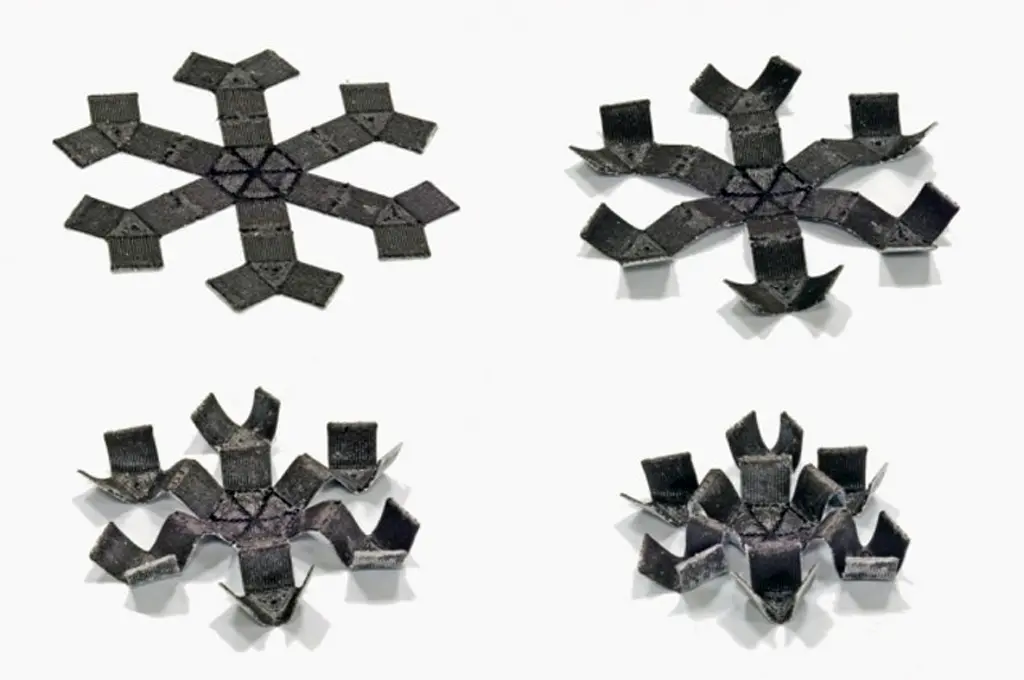
The menagerie of structures that can be magnetically manipulated includes a smooth ring that wrinkles up, a long tube that squeezes shut, a sheet that folds itself, and a spider-like “grabber” that can crawl, roll, jump, and snap together fast enough to catch a passing ball. It can even be directed to wrap itself around a small pill and carry it across a table.

The researchers fabricated each structure from a new type of 3-D-printable ink that they infused with tiny magnetic particles. They fitted an electromagnet around the nozzle of a 3-D printer, which caused the magnetic particles to swing into a single orientation as the ink was fed through the nozzle. By controlling the magnetic orientation of individual sections in the structure, the researchers can produce structures and devices that can almost instantaneously shift into intricate formations, and even move about, as the various sections respond to an external magnetic field.

Xuanhe Zhao, the Noyce Career Development Professor in MIT’s Department of Mechanical Engineering and Department of Civil and Environmental Engineering, says the group’s technique may be used to fabricate magnetically controlled biomedical devices.

“We think in biomedicine this technique will find promising applications,” Zhao says. “For example, we could put a structure around a blood vessel to control the pumping of blood, or use a magnet to guide a device through the GI tract to take images, extract tissue samples, clear a blockage, or deliver certain drugs to a specific location. You can design, simulate, and then just print to achieve various functions.”

Zhao and his colleagues have published their results today in the journal Nature. His co-authors include Yoonho Kim, Hyunwoo Yuk, and Ruike Zhao of MIT, and Shawn Chester of the New Jersey Institute of Technology.

A shifting field

The team’s magnetically activated structures fall under the general category of soft actuated devices — squishy, moldable materials that are designed to shape-shift or move about through a variety of mechanical means. For instance, hydrogel devices swell when temperature or pH changes; shape-memory polymers and liquid crystal elastomers deform with sufficient stimuli such as heat or light; pneumatic and hydraulic devices can be actuated by air or water pumped into them; and dielectric elastomers stretch under electric voltages.

But hydrogels, shape-memory polymers, and liquid crystal elastomers are slow to respond, and change shape over the course of minutes to hours. Air- and water-driven devices require tubes that connect them to pumps, making them inefficient for remotely controlled applications. Dielectric elastomers require high voltages, usually above a thousand volts.

“There is no ideal candidate for a soft robot that can perform in an enclosed space like a human body, where you’d want to carry out certain tasks untethered,” Kim says. “That’s why we think there’s great promise in this idea of magnetic actuation, because it is fast, forceful, body-benign, and can be remotely controlled.”

Other groups have fabricated magnetically activated materials, though the movements they have achieved have been relatively simple. For the most part, researchers mix a polymer solution with magnetic beads, and pour the mixture into a mold. Once the material cures, they apply a magnetic field to uniformly magnetize the beads, before removing the structure from the mold.

“People have only made structures that elongate, shrink, or bend,” Yuk says. “The challenge is, how do you design a structure or robot that can perform much more complicated tasks?”

Domain game

Instead of making structures with magnetic particles of the same, uniform orientation, the team looked for ways to create magnetic “domains” — individual sections of a structure, each with a distinct orientation of magnetic particles. When exposed to an external magnetic field, each section should move in a distinct way, depending on the direction its particles move in response to the magnetic field. In this way, the group surmised that structures should carry out more complex articulations and movements.

With their new 3-D-printing platform, the researchers can print sections, or domains, of a structure, and tune the orientation of magnetic particles in a particular domain by changing the direction of the electromagnet encircling the printer’s nozzle, as the domain is printed.

The team also developed a physical model that predicts how a printed structure will deform under a magnetic field. Given the elasticity of the printed material, the pattern of domains in a structure, and the way in which an external magnetic field is applied, the model can predict the way an overall structure will deform or move. Ruike found that the model’s predictions closely matched with experiments the team carried out with a number of different printed structures.

In addition to a rippling ring, a self-squeezing tube, and a spider-like grabber, the team printed other complex structures, such as a set of “auxetic” structures that rapidly shrink or expand along two directions. Zhao and his colleagues also printed a ring embedded with electrical circuits and red and green LED lights. Depending on the orientation of an external magnetic field, the ring deforms to light up either red or green, in a programmed manner.

“We have developed a printing platform and a predictive model for others to use. People can design their own structures and domain patterns, validate them with the model, and print them to actuate various functions,” Zhao says. “By programming complex information of structure, domain, and magnetic field, one can even print intelligent machines such as robots.”

Jerry Qi, professor of mechanical engineering at Georgia Tech, says the group’s design can enable a range of fast, remotely controlled soft robotics, particularly in the biomedical field.

“This work is very novel,” says Qi, who was not involved in the research. “One could use a soft robot inside a human body or somewhere that is not easily accessible. With this technology reported in this paper, one can apply a magnetic field outside the human body, without using any wiring. Because of its fast responsive speed, the soft robot can fulfill many actions in a short time. These are important for practical applications.”

This research was supported, in part, by the National Science Foundation, the Office of Naval Research, and the MIT Institute for Soldier Nanotechnologies.
Related

Recent Posts

Bourns SM91522AL BMS signal transformer with integrated common-mode chokes

Bourns Releases BMS Transformer with 3.5 mm Height

21.10.2026
1
Modelithics COMPLETE+3D v26.4 library for RF passive-component and 3D electromagnetic simulation in Keysight ADS/RFPro

Modelithics COMPLETE+3D v26.4 Expands RF Models and 3D Workflows

19.10.2026
8
Features of BCZT and strontium titanate dielectric layers in a thin-film superlattice

Relaxor superlattice capacitors approach 99% efficiency

12.10.2026
31
Conceptual Toray heat-resistant film capacitor beside an inverter cooling structure.

Toray Film Capacitor Enables 150°C Inverter Operation

9.10.2026
68
Panasonic Industry PGS graphite heat-spreading technology and passive components for spacecraft thermal management

Panasonic Targets Space Thermal Design at SPCD 2026

8.10.2026
41
tungsten-bronze-ceramic-capacitor-stack

Tungsten bronze capacitors combine high κ and thermal stability

7.10.2026
39
Datasheet-style illustration of a TDK MLJ1608-G multilayer chip inductor with end terminals

TDK Expands1608 Inductors for Automotive PoC Filters

6.10.2026
12
Ruggedized passive component customization overview covering capacitors, resistors and inductors.

Ruggedized Passive Components: Reliability Beyond the Datasheet

6.10.2026
52
YAGEO Group PMT6709NLT and PHT7249NLT GDSC SMD LLC gate-drive transformers for SiC and GaN switching applications

YAGEO Introduces LLC Transformers for SiC and GaN Gate Drives

2.10.2026
41

Upcoming Events

Oct 27
15:00 - 16:00 CET

Heraeus Electronics Webinar: What materials perform when failure is not an option?

Oct 27
16:00 - 17:00 CET

Power Inductor technologies

Oct 28
13:00 - 14:00 CDT

Inductor Design in a Multi-Phase Buck Converter

View Calendar

Popular Posts

  • Buck Converter Design and Calculation

    0 shares
    Share 0 Tweet 0
  • Boost Converter Design and Calculation

    0 shares
    Share 0 Tweet 0
  • LLC Resonant Converter Design and Calculation

    0 shares
    Share 0 Tweet 0
  • Capacitor Charging and Discharging

    0 shares
    Share 0 Tweet 0
  • Flyback Converter Design and Calculation

    0 shares
    Share 0 Tweet 0
  • Audio Capacitors: Choosing Capacitors for Crossover Circuits

    0 shares
    Share 0 Tweet 0
  • MLCC and Ceramic Capacitors

    0 shares
    Share 0 Tweet 0
  • RF Connector Types: How To Choose the Right One

    0 shares
    Share 0 Tweet 0
  • Thermistors Basics, NTC and PTC Thermistors

    0 shares
    Share 0 Tweet 0
  • Passive Low Pass Filters: Fundamentals and EMI Design

    0 shares
    Share 0 Tweet 0

Newsletter Subscription


Passive Components Blog

© 2015–2026
All rights reserved

  • Home
  • Privacy Policy
  • EPCI Membership & Advertisement
  • About

No Result
View All Result
  • Home
  • Knowledge Blog
  • Dossiers
  • PCNS

© 2015–2026
All rights reserved