This article is based on edited newsletter written by Pablo Blázquez, Frenetic power electronics engineer that explores a key player in power supply design, the Flyback Transformer.
A flyback transformer is an energy-storing coupled inductor that provides voltage conversion and, when appropriately constructed, galvanic isolation in a switching power supply. This guide explains flyback transformer design for power-supply engineers, from operating mode and turns ratio to core selection, winding construction, losses, safety and production validation. A 24 W adapter example connects the electrical calculations to practical transformer specifications.
Key Takeaways
Successful design requires the magnetic component, controller and power stage to be evaluated together.
- A flyback transformer stores energy while the primary switch conducts and delivers it through the secondary after the switch turns off; in a conventional gapped ferrite construction, most stored magnetic energy resides in the gap.
- Turns ratio must satisfy demagnetization time, controller limits and both primary-switch and secondary-rectifier voltage stress. The CCM conversion ratio cannot be applied unchanged to DCM operation with an idle interval.
- Magnetizing inductance, peak current, winding RMS currents and flux swing must be checked across input voltage, load, temperature and manufacturing tolerances.
- Low leakage inductance, low interwinding capacitance, insulation integrity and low winding loss are competing construction objectives, not independent specifications.
- Active-clamp and GaN-based converters require deliberate control of parasitic inductance, capacitance and circulating current; their transformer waveforms should not be sized using conventional DCM equations alone.
- A production-ready transformer requires a controlled construction drawing, specified measurement conditions, thermal verification and the insulation qualification appropriate to the end equipment.
This article develops material originally based on an edited newsletter by Pablo Blázquez, a power electronics engineer at Frenetic.
Operating Principle
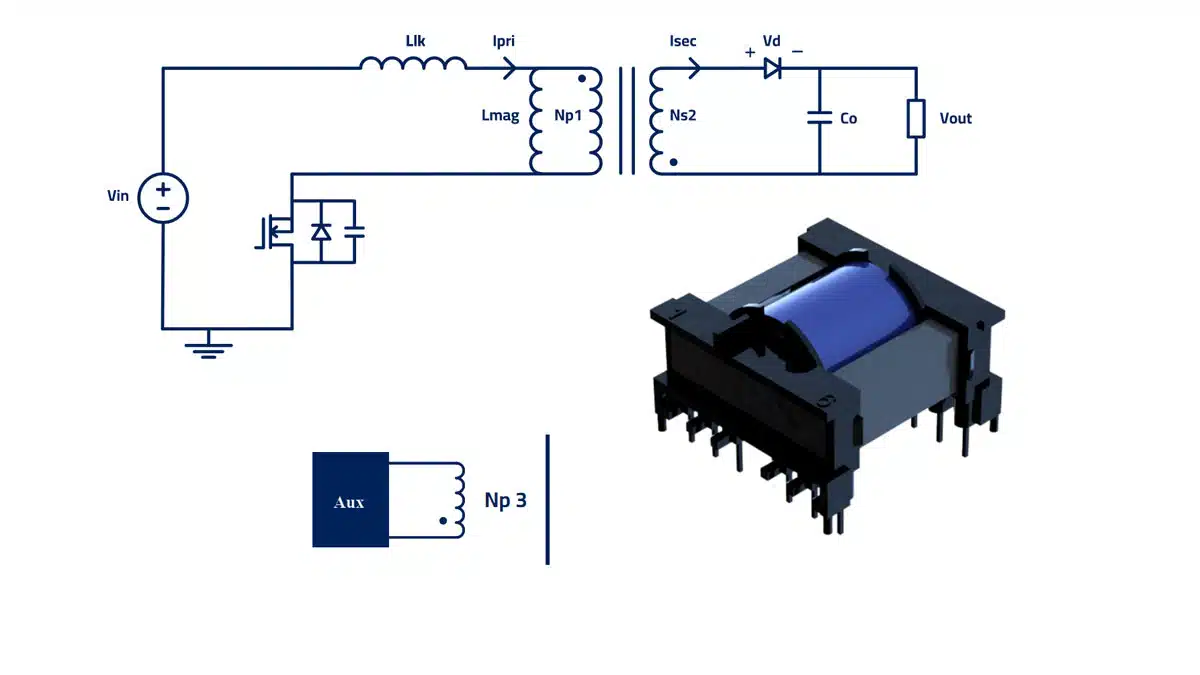
A flyback converter separates energy storage and delivery into different parts of the switching cycle. Unlike a forward converter transformer, its magnetic component must accommodate a substantial stored-energy requirement as well as the required insulation barrier. The discussion here concerns power-conversion magnetics, not signal transformers. [1, 2]
During the primary MOSFET on-time, the input voltage is applied to the primary winding. Magnetizing current increases, while the winding polarity reverse-biases the secondary rectifier. The output capacitor supplies the load during this interval. When the MOSFET turns off, the winding voltages reverse and the secondary rectifier conducts, delivering energy to the load and recharging the output capacitor.
For a linear magnetizing inductance Lp, the peak stored energy Epk is given by Eq. (1), where Ip,pk is the peak primary-referred magnetizing current. In a conventional gapped ferrite structure, the gap dominates reluctance and stores most of this energy; the ferrite guides the magnetic flux. [2]
DCM, CCM and boundary operation
In discontinuous conduction mode, or DCM, the secondary current reaches zero before the next primary switching pulse. A finite idle interval remains after demagnetization. Relative to a comparable CCM design, DCM generally involves higher peak currents and can increase RMS-current and capacitor-ripple requirements, but avoids forced turn-off of a conducting secondary diode and does not have the conventional CCM right-half-plane zero. [1]
In continuous conduction mode, or CCM, the primary-referred magnetizing current remains above zero between energy-storage intervals. The physical primary and secondary winding currents still alternate: continuous magnetizing current does not mean that both windings conduct continuously. CCM can reduce peak and RMS currents, but the power-stage control-to-output response includes a right-half-plane zero that constrains loop compensation. [3]
Boundary or critical conduction operation lies at the transition between DCM and CCM. Quasi-resonant, or QR, control usually adds deliberate turn-on timing at a drain-voltage valley after demagnetization. Boundary operation and QR valley switching are therefore related concepts, but not interchangeable descriptions of an identical waveform. Switching frequency may vary with line, load and valley selection. [1, 2]
Application Context and Use Cases
Flyback converters are used in isolated adapters, LED drivers and auxiliary supplies where circuit simplicity and a compact magnetic component are useful. The transformer must be selected for the actual regulation, insulation and thermal requirements rather than for output power alone. [1, 4]
In an AC–DC adapter, the transformer contributes to the protective insulation between the mains-referenced primary and accessible output. In an LED driver, the complete converter regulates output current or voltage; the transformer itself does not provide regulation. Industrial auxiliary rails, isolated sensor supplies and feedback supplies may need modest output power but demanding insulation, transient or environmental performance.
Multi-output designs add cross-regulation constraints. Outputs sharing the same magnetic component do not necessarily remain within tolerance under arbitrary loading, and secondary windings are not automatically insulated from each other to the same level as the primary-to-secondary barrier. Specify every required isolation relationship and cross-load condition.
The magnetic design must simultaneously accommodate electrical loading, required creepage and clearance, insulation thickness, ambient temperature, cooling and manufacturing tolerances. These requirements influence core geometry, bobbin construction, wire system, switching frequency and the arrangement of primary, secondary and auxiliary windings.
Topologies and Their Characteristics
Switching method, conduction mode and output configuration describe different aspects of a converter. Table 1 separates these categories and retains forward and half-bridge converters as alternatives for comparison, not as flyback variants. Power alone does not establish a universal boundary between them. [1, 3, 5]
| Configuration | Category | Main characteristic | Transformer design consequence |
|---|---|---|---|
| Hard-switched flyback | Switching method | Simple power stage with turn-on and turn-off losses | Control leakage-related overshoot, winding loss and EMI; provide a suitable clamp or snubber. |
| Boundary or QR flyback | Conduction and switching strategy | Demagnetization-based timing; valley turn-on may reduce switching loss | Check magnetizing inductance, parasitic capacitance and timing over the full operating range. |
| Active-clamp flyback | Clamp and switching topology | Recovers leakage energy and can enable zero-voltage switching | Specify leakage, magnetizing inductance, clamp interaction and circulating-current limits together. |
| Single-output flyback | Output configuration | One principal regulated output | Size the secondary for the required peak and RMS currents. |
| Multi-output flyback | Output configuration | Several outputs share one magnetic component | Evaluate cross-regulation, winding placement, auxiliary sensing and insulation between outputs. |
| Forward or half-bridge converter | Alternative converter family | Transfers energy through the transformer during an applied primary-voltage interval | Design transformer reset and flux balance; energy storage and output filtering differ from flyback practice. |
Active-clamp, GaN and planar implementations
An active-clamp flyback adds a controlled switch and clamp capacitor. Instead of dissipating leakage energy in a conventional passive clamp, the circuit can recycle it through the power stage. Suitable control of resonant transitions can also enable zero-voltage switching, or ZVS. Neither benefit is guaranteed at every line and load condition. [5]
GaN switching devices can reduce the energy required for these transitions and support higher-frequency operation. For transformer design, the important consequence is the need to include negative magnetizing current, resonant current and the complete switching waveform in RMS-current and loss calculations. Lower inductance or a smaller core does not automatically produce lower temperature.
Planar windings can provide a low-profile construction and controlled geometry, but PCB layer arrangement, interwinding capacitance, insulation and AC copper loss remain central design constraints. Treat the controller, semiconductor capacitances, transformer parasitics and clamp network as an interacting system rather than selecting a transformer from turns ratio and inductance alone. [5]
From Requirements to Transformer Specifications
Begin with a written specification covering electrical operation, environment, safety and production. For an offline supply, distinguish the AC input rating from the actual DC voltage across the bulk capacitor, including ripple and hold-up conditions.
- Input: minimum and maximum AC or DC voltage, bulk-capacitor valley voltage, line frequency, brownout, surge and hold-up requirements.
- Outputs: output voltage Vo, maximum output current Io,max, maximum output power Po,max, number of outputs, transient limits and cross-load combinations.
- Control: controller type, DCM/CCM/QR or active-clamp operation, switching-frequency range fsw, maximum duty cycle, minimum on-time, minimum off-time and current-limit behavior.
- Efficiency: overall converter target ηsys, together with separate allowances for rectification, switching, magnetics, clamp, control and auxiliary-power losses.
- Insulation: working voltage, required basic or reinforced insulation, isolation between individual windings, applicable equipment standard and dielectric-test requirements.
- Environment and mechanics: ambient temperature, enclosure, airflow, maximum hotspot temperature, footprint, height, mounting, vibration and manufacturing process.
Derived transformer targets include primary magnetizing inductance, turns ratio, peak and RMS winding currents, flux swing, leakage inductance, winding resistance, interwinding capacitance and permissible losses. These targets must include tolerances and measurement conditions; nominal values alone do not define an interchangeable component.
For audio/video and information and communication technology equipment, IEC 62368-1:2023 provides the relevant product-safety framework. IEC 61558-2-16:2021, with its applicable corrigendum, addresses switch-mode power supply units and transformers for general applications within that standard’s scope. The applicable national adoption, edition and certification route must be established for the end product. [6, 7]
Flyback Transformer Design: Electrical Methodology
The following sequence applies to a conventional single-output flyback with approximately linear magnetizing inductance. DCM equations assume triangular current pulses starting or ending at zero; CCM and active-clamp waveforms require their corresponding models. The calculations are iterative because timing, voltage stress, losses and available construction space constrain one another. [1, 3]
Select operating mode and switching frequency
Choose the operating mode using output power, input range, controller capability, transient response, current stress and efficiency targets. For QR designs, use the controller’s frequency-versus-line-and-load behavior rather than treating nominal frequency as a fixed value.
Increasing switching frequency reduces the energy processed per cycle for a given power, but can increase switching loss, AC winding loss and core-loss density. Compare candidate frequencies using a complete loss and temperature estimate, not a presumed proportional reduction in transformer size. [2, 5]
Estimate turns ratio and reflected voltage
Define n as the primary-to-secondary turns ratio, Np/Ns. During secondary conduction, the output voltage plus rectifier forward drop Vf is reflected onto the primary as VR, according to Eq. (2). This is the primary-referred secondary voltage, not the secondary voltage itself. [1]
Let T = 1/fsw be the switching period, D = ton/T the primary on-time fraction, D2 = tdemag/T the secondary conduction fraction and D0 the idle fraction. For idealized DCM timing, volt-second balance gives Eq. (3), where Vin is the DC voltage applied to the primary while the switch conducts.
Eq. (3) shows why a desired duty cycle alone is insufficient to determine turns ratio in DCM: the demagnetization and idle intervals must also be specified. At the ideal boundary, D0 = 0. For conventional CCM steady state, the same voltage conversion relation uses the full off-time, giving Eq. (4).
Choose reflected voltage by balancing primary-switch voltage stress against secondary-rectifier voltage stress and available demagnetization time. Eq. (5) gives first-order flat-top voltages: VDS,flat is the primary MOSFET off-state plateau and Vrev,flat is the secondary rectifier reverse-voltage plateau. Leakage-related overshoot and ringing are additional stresses, not included in these values. [1, 3]
Include line tolerance, output tolerance, clamp behavior, transient overshoot and device derating before selecting voltage ratings. A reflected-voltage fraction of the minimum input is not a substitute for these checks.
Determine primary inductance and peak current
For DCM, the stored magnetizing energy is released each cycle. Define Pmag as the average magnetizing energy processed per second and ηE as the fraction reaching the specified output. Eq. (6) relates these quantities to output power Po. ηE is an energy-transfer factor for this model; it is not automatically equal to overall converter efficiency ηsys. [1, 4]
The primary current ramp and on-time give Eq. (7). Switch and sense-resistor voltage drops are neglected here; include them when their contribution is significant.
Check current-limit threshold tolerance, current-sense resistance, leading-edge blanking and propagation delay. The lowest inductance can produce the fastest current rise, while the highest inductance can increase required on-time or demagnetization time under other operating constraints. Evaluate the combinations rather than choosing one tolerance corner for every check.
In CCM, some magnetizing energy remains at the end of the cycle. Eq. (8) therefore uses the difference between peak and minimum energy; Im,min is the minimum primary-referred magnetizing current. The DCM peak-energy expression must not be used unchanged when Im,min is nonzero.
Check the CCM/DCM boundary
For a fixed-frequency design intended to remain in DCM, verify that the on-time plus demagnetization time leaves the required idle interval at maximum intended load across the input range. Low input and high load are often important, but controller frequency changes, inductance tolerance and current-limit behavior can move the limiting condition. Light-load operation alone does not establish full-load DCM capability. [1]
Eq. (9) calculates demagnetization time for the simplified DCM waveform. A QR controller also needs time for its selected resonant valley and minimum-off-time constraints; the available interval is not defined by demagnetization alone.
Calculate secondary and RMS currents
For an ideal single-output DCM flyback, secondary peak current Is,pk is the primary peak current multiplied by n. Eq. (10) gives full-period primary and secondary RMS currents, Ip,rms and Is,rms, and the average secondary current Is,avg. At steady output voltage, Is,avg equals load current when no other branch draws secondary current. [1, 4]
Use RMS current for winding-loss calculations and peak current for rectifier, switch and saturation checks. For CCM, use the actual trapezoidal waveform. In a multi-output transformer, current sharing depends on winding voltages, rectifier drops, leakage and loading; do not assign the entire primary peak current independently to every output.
Core Selection and Gap Design
The core and bobbin must provide both sufficient magnetic capability and enough usable winding space. A candidate that meets inductance and flux calculations can still fail because insulation margins, wire build, terminations or temperature rise do not fit the available construction. [2, 4]
Core shape and material
Common ferrite geometries include EE, EF, ER, RM, PQ and related low-profile forms. Compare effective core cross-sectional area Ae, effective volume, magnetic path length, winding-window area Aw, mean turn length, bobbin options and mounting requirements. Select the material using loss data and saturation behavior at the intended frequency and temperature.
- Check that the core cross-section supports the required volt-seconds with suitable flux margin.
- Reserve window area for actual insulated-wire dimensions, interlayer insulation, winding margins and manufacturing variation.
- Confirm that the bobbin and terminal arrangement support the required creepage, clearance and winding-to-core insulation.
- Compare loss and saturation information over the intended temperature range, not only at room temperature.
Flux density and primary turns
The flux-density swing ΔB during the primary on-time follows Eq. (11). For the linear magnetic model, it can also be calculated from magnetizing-current swing ΔIm. These relations establish the minimum turns needed for a chosen allowable flux swing.
For DCM, magnetizing current returns approximately to zero, although ferrite remanence means absolute flux need not return to zero. In CCM, peak flux also includes the DC magnetizing-current component; flux swing alone is insufficient for the saturation check. Use material-specific saturation data and an appropriate allowance for temperature, remanence, tolerances and transient operation. [2, 4]
Check the largest applied volt-second product and the highest permitted magnetizing current during normal operation, startup and abnormal conditions. Maximum input voltage is not automatically the worst saturation condition in a regulated converter, because the controller changes on-time with input voltage.
Inductance factor and air gap
Let ℛmag be total magnetic reluctance and AL the inductance factor of the assembled core set. Eq. (12) relates them to primary turns. Inductance alone does not uniquely determine a safe turns-and-gap combination: first establish adequate turns from flux and construction constraints, then select the gap or AL required to obtain Lp.
For a gap-dominated magnetic circuit with an approximately uniform cross-section, Eq. (13) gives a first estimate of total effective gap length lg, where µ0 is the permeability of free space. This estimate neglects ferrite reluctance and fringing; use the core supplier’s gapped-core data and verify the assembled component.
A larger localized gap can increase fringing field near the winding and create additional conductor loss. Gap location, winding setback and assembly tolerances therefore belong in the construction specification, not just in the nominal inductance calculation.
Estimate core loss with manufacturer data or a validated waveform-dependent model using frequency, temperature and the actual flux waveform. Check whether a published curve defines flux as peak amplitude or peak-to-peak swing; substituting one for the other can materially distort the estimate. [2, 4]
Winding Design and Layout
Winding construction determines resistance, leakage inductance, parasitic capacitance, insulation integrity and much of the production variability. Optimize these characteristics together rather than minimizing one parameter without considering its consequences. [2]
Wire selection
Choose conductor cross-section from RMS current, permissible winding loss, winding length and the thermal environment. Use hot winding resistance in the loss estimate. Current density is an initial sizing aid, not a universal acceptance limit.
Skin and proximity effects raise effective resistance at switching frequency and its harmonics. Compare solid wire, parallel conductors, foil and litz wire using the actual waveform and winding arrangement. Parallel strands do not automatically provide the same high-frequency current distribution as a properly designed litz construction. [2]
- Use the finished wire diameter, including insulation, when checking bobbin fill.
- Include termination resistance and the manufacturability of multiple strands or litz terminations.
- Check AC loss in conductors near a localized air gap and in multilayer windings.
Layering, leakage and coupling
A split-primary arrangement, such as primary–secondary–primary, can reduce leakage inductance by improving coupling. It also introduces additional primary-to-secondary interfaces and may increase capacitance or complicate insulation. Choose winding order from the combined loss, EMI, regulation and safety requirements. [2, 4]
Interwinding capacitance couples displacement current across the isolation barrier. The location of the high-dv/dt switching end of the primary relative to the secondary can therefore matter as much as total capacitance. Winding orientation, shielding and terminal assignment should be evaluated in the complete converter.
For multi-output transformers, prioritize coupling according to power, regulation and sensing requirements. An auxiliary winding used for controller bias or primary-side regulation needs suitable coupling to the sensed output and must remain within its own voltage limits across cross-loading conditions.
In a hard-switched flyback, excessive leakage increases clamp demand and voltage overshoot. In an active-clamp design, leakage participates in resonant transitions, so the objective is a controlled value and tolerance rather than an unspecified minimum. [5]
Insulation, creepage and clearance
Creepage is the distance along an insulating surface; clearance is the distance through air. Both must be assessed for the applicable insulation system and operating environment. A winding wire’s dielectric rating alone does not establish the safety of the completed transformer.
- Specify working voltage, required insulation category, pollution degree, altitude and the applicable equipment standard.
- Use suitable bobbins, margin systems, interwinding insulation or approved insulated-wire systems, including appropriate termination treatment.
- Maintain safety-critical dimensions under worst-case winding placement, lead routing and assembly tolerances.
- Document insulation to the core and between separate secondary circuits where those barriers are required.
Losses and Thermal Considerations
Transformer temperature is driven principally by losses generated in its core and windings, together with heat received from neighboring components. Converter-level clamp, switch and rectifier losses must also be budgeted, but their heat is not automatically generated inside the transformer.
For a DC-resistance-only estimate, Eq. (14) sums copper loss PCu,DC over the windings indexed by k, using each winding’s RMS current Ik,rms and DC resistance RDC,k at its operating temperature. This is a baseline; add the extra loss caused by skin, proximity and fringing effects. [2, 4]
For a frequency-dependent calculation, resolve winding current into its DC and harmonic components and apply the corresponding resistance to each component. Avoid counting the same AC loss twice by adding a full AC-resistance estimate to an RMS-current loss term that already includes it.
Estimate core loss from the chosen material’s data and actual excitation. Add construction-related stray losses where relevant. A lumped thermal model can provide an initial temperature-rise estimate, but hotspot temperature depends on the distribution of loss, winding build, core contact, enclosure and airflow.
Leakage energy contributes to external clamp or snubber dissipation in a conventional flyback. Its influence belongs in the complete converter loss budget and surrounding thermal model. For an active-clamp converter, include losses from the recovery path and circulating current rather than treating recovered energy as an unavoidable resistor loss. [2, 5]
Verify temperature after thermal stabilization in the intended enclosure and cooling conditions. Check both core and winding limits, and do not infer the winding hotspot solely from the visible core surface temperature.
Example Design Outline: 24 W Adapter
The original example is a universal-input adapter delivering 12 V at 2 A, with a nominal switching frequency of 65 kHz and an overall efficiency target of 85–88%. The calculation below retains that application and develops one explicit fixed-frequency DCM operating point. It is a preliminary electrical and magnetic example, not a qualified transformer or a complete QR-controller design.
Input assumptions and power accounting
Retain the 90–265 V AC input specification. The ideal rectified sine-wave peaks are approximately 127.3 V and 374.8 V before bridge drops. A stated 120–375 V DC operating range is therefore not a direct RMS-to-DC conversion: the lower value must be established from bulk-capacitor ripple, loading, line frequency and hold-up requirements.
For this calculation, assume that the converter has a verified minimum bulk voltage of 120 V and a maximum normal bulk voltage of 375 V. Use 65 kHz fixed-frequency operation, a low-line on-time fraction D = 0.40, a primary-to-secondary turns ratio n = 8 and a constant secondary-diode drop Vf = 0.6 V.
For a transparent waveform calculation, initially neglect transformer and clamp losses while including secondary-diode conduction loss. The output is 24 W, diode loss is 1.2 W and the magnetizing energy processed per second is therefore 25.2 W. This gives ηE = 24/25.2 = 0.9524 for Eq. (6). The separate 85–88% overall efficiency target implies input power of approximately 28.24–27.27 W; it is not substituted into the secondary-current calculation as though all converter losses occurred after magnetizing-energy storage.
Timing, inductance and current
From Eq. (2), VR = 8 × (12 + 0.6) = 100.8 V. Eq. (3) then gives D2 = 120 × 0.40/100.8 = 0.4762 and D0 = 0.1238. The assumed low-line operating point is therefore in DCM, with an idle interval available before the next switching cycle.
Using Eq. (7), Lp is approximately 703 µH and Ip,pk is 1.05 A. The primary on-time is 6.15 µs and demagnetization takes 7.33 µs. These values leave approximately 1.90 µs of idle time within the 15.38 µs switching period.
Eq. (10) gives a secondary peak current of 8.40 A, primary RMS current of 0.383 A and secondary RMS current of 3.35 A. The average secondary current is 8.40 × 0.4762/2 = 2.00 A, consistent with the specified load and the explicit diode-loss model.
At 375 V, maintaining the same peak current and fixed frequency reduces D to approximately 0.128. The demagnetization fraction remains approximately 0.4762 in this simplified constant-output model, increasing the idle fraction to approximately 0.3958. A real QR controller would instead change frequency and valley timing according to its control law.
| Parameter | Calculated value | Interpretation |
|---|---|---|
| Output power | 24 W | 12 V at 2 A |
| Magnetizing energy processed per second | 25.2 W | Includes the assumed secondary-diode loss only |
| Primary-referred secondary voltage | 100.8 V | Turns ratio 8 with 0.6 V diode drop |
| Primary magnetizing inductance | 703 µH | Preliminary nominal value |
| Primary peak current | 1.05 A | Before tolerances and transient margin |
| Primary RMS current at 120 V | 0.383 A | Full-period triangular waveform |
| Secondary peak current | 8.40 A | Ideal current commutation |
| Secondary RMS current | 3.35 A | Full-period triangular waveform |
| Primary-switch flat-top voltage at 375 V | 475.8 V | Excludes overshoot and surge |
| Rectifier reverse-voltage plateau at 375 V | 58.9 V | Excludes ringing and transient margin |
Illustrative turns and gap calculation
To illustrate the magnetic calculations without claiming a particular catalog core, assume Ae = 60 mm², Np = 80 turns and Ns = 10 turns. Eq. (11) gives ΔB ≈ 0.154 T at the calculated low-line operating point. Eq. (12) gives a required AL of approximately 110 nH per turn squared.
Eq. (13) gives an approximate total effective gap of 0.686 mm before correction for ferrite reluctance and fringing. This is not a machining instruction: the final gap must come from the chosen core geometry, material, assembly and measured AL. The assumed cross-section does not establish sufficient window area, acceptable loss or safe operating temperature.
Next select an actual EE or ER core and compatible bobbin, check material loss at the intended waveform and temperature, and determine whether the windings and insulation fit. Iterate turns, gap, conductor arrangement or core size as necessary. Include transformer, clamp and auxiliary losses in the refined power model, then repeat the current, timing and temperature checks.
Finally, verify the result against controller tolerances, startup, current limit, abnormal loading and actual switching waveforms. The calculated 475.8 V MOSFET plateau and 58.9 V rectifier plateau are not sufficient on their own to select device voltage ratings.
Design and Selection Checklist
A purchasing specification should translate the design calculations into measurable acceptance criteria. Compare catalog and custom transformers using the same operating and test conditions, not only nominal inductance and turns ratio.
| Parameter | What to specify or compare | Why it matters |
|---|---|---|
| Turns and polarity | Every winding ratio, dot convention, pin assignment and permitted tolerance | Determines output voltage, sensing behavior and correct commutation. |
| Magnetizing inductance | Nominal value, tolerance, test frequency, test amplitude, temperature and bias condition | Controls current ramp, timing and stored-energy capability. |
| Leakage inductance | Measured winding, shorted windings, test frequency and fixture arrangement | Influences overshoot, clamp loss and resonant behavior. |
| Current capability | Peak-current limit, inductance-versus-current behavior and RMS-current conditions | Separates saturation capability from thermal capability. |
| Winding resistance | Maximum DC resistance at a stated temperature; AC-loss information where available | Supports hot copper-loss and temperature estimates. |
| Capacitance and EMI | Relevant winding-to-winding capacitance and terminal configuration | Supports common-mode-noise and switching-transition evaluation. |
| Insulation system | Working voltage, insulation category, construction approval and required tests | Prevents a dielectric-test voltage from being mistaken for a continuous working-voltage rating. |
| Thermal and mechanical limits | Ambient conditions, hotspot limit, dimensions, mounting and assembly process | Establishes suitability for the actual enclosure and production process. |
Catalog versus custom transformers
A catalog transformer can simplify sourcing when its winding set, insulation, package and characterized operating conditions match the application. A custom design allows control of turns, gap, wire, shielding and winding arrangement when regulation, height, parasitics or insulation requirements cannot be met by an existing part.
For either route, obtain a controlled specification and representative samples. For custom parts, define winding order, materials, insulation build, terminations and permitted substitutions. A second source with matching nominal inductance and ratio is not necessarily electrically, thermally or safety-equivalent.
Safety, Compliance and Validation
Production release requires evidence that the transformer meets electrical, thermal, insulation and manufacturing requirements in the intended converter. Qualification should connect the approved construction to repeatable measurements and to the applicable end-equipment safety assessment.
Safety documentation and tests
Document the insulation barriers, materials, winding arrangement, creepage and clearance dimensions, working voltages and required dielectric withstand tests. Use the applicable product standard and certification plan to determine test voltage, waveform, duration, acceptance criteria and production-test requirements. Partial-discharge testing is applied where required by that assessment; it is not a universal requirement for every flyback transformer. [6, 7]
IEC 62368-1:2023 is an equipment-safety standard for audio/video and ICT equipment, not a generic transformer design recipe. Likewise, IEC 61558-2-16 must be applied within its scope and relevant standards framework. Do not infer universal winding distances or test voltages from a standard number alone.
Electrical and thermal measurements
- Measure magnetizing inductance with the other windings open, using the specified frequency and test amplitude; assess bias and temperature dependence where relevant.
- Measure leakage inductance with the specified coupled windings shorted using short, low-inductance connections. Record which windings are shorted and the measurement reference side.
- Verify turns ratio, polarity, DC resistance and relevant capacitances using a documented terminal configuration.
- Measure primary and secondary waveforms, current peaks, demagnetization, switch overshoot and rectifier ringing in the complete converter.
- Check stabilized temperature at the limiting line, load, ambient and cooling conditions, including enclosure effects.
EMI and manufacturing consistency
Evaluate conducted and radiated emissions using the actual transformer, PCB layout, cables and enclosure. Changes to winding orientation, shielding or interleaving may improve one aspect of EMI while changing capacitance, leakage or winding loss, so repeat the relevant electrical and thermal checks after each construction revision. [2]
Characterize production-representative samples to establish the distribution of inductance, leakage, resistance and insulation performance. Freeze safety-critical construction details and require change notification for core material, gap process, bobbin, wire, insulation, varnish and winding arrangement. Correlate acceptance tests with the failure modes they are intended to prevent.
Conclusion
A successful flyback transformer combines stored-energy capability, controlled voltage conversion, suitable insulation and acceptable temperature rise in a reproducible construction. Turns ratio and inductance are starting points, not a complete specification: demagnetization time, current waveforms, flux, parasitics and thermal behavior must remain compatible across the operating range.
Conventional DCM and CCM designs benefit from a disciplined analytical sequence followed by prototype verification. Active-clamp, GaN and planar implementations preserve the same need for magnetic and insulation discipline while making parasitic control and waveform-dependent losses more important. Production confidence comes from a validated converter and a controlled transformer construction, not from a nominal power rating alone.
FAQ
These answers summarize the operating, design and purchasing questions addressed in the article.
A flyback transformer is a coupled inductor used to store energy during primary-switch conduction and deliver it through a secondary winding after turn-off. Appropriate construction also provides galvanic isolation. Applications include adapters, LED drivers and auxiliary power supplies. The complete converter controls output regulation, while the transformer must meet magnetic, thermal and insulation requirements.
In DCM, secondary current reaches zero before the next primary pulse, leaving an idle interval. In CCM, primary-referred magnetizing current remains above zero between storage intervals. Boundary operation is the transition between them. Quasi-resonant control usually times turn-on at a drain-voltage valley after demagnetization, so its frequency and available timing must be checked across line and load.
Define turns ratio as primary turns divided by secondary turns. The primary-referred secondary voltage equals this ratio multiplied by output voltage plus rectifier drop. Choose it by balancing demagnetization time, primary-switch voltage stress, secondary-rectifier stress and controller limits. In DCM, include the secondary conduction and idle intervals rather than using the CCM conversion equation unchanged.
For DCM, magnetizing energy processed per cycle is half the primary inductance multiplied by peak current squared. Multiplying by switching frequency gives processed magnetic power. Account separately for the fraction reaching the output and for overall converter losses. Then verify the current ramp, on-time, demagnetization, controller current limit and winding RMS currents across operating conditions and tolerances.
Choose a core and bobbin with sufficient magnetic cross-section, winding space and insulation capability. Establish primary turns from allowable flux and applied volt-seconds, then select the gap or inductance factor needed for magnetizing inductance. Check material-specific saturation and loss data at operating temperature. Inductance alone cannot establish a safe turns count or an acceptable core temperature.
Select conductors from RMS current, hot resistance and high-frequency loss, then arrange windings to balance leakage inductance, capacitance, insulation and regulation. A split primary can improve coupling but may increase capacitance or insulation complexity. Check winding orientation and auxiliary sensing in the complete converter. Multi-output designs also require cross-load verification rather than independent single-output current assumptions.
An active clamp can recover leakage energy and enable zero-voltage switching through controlled resonant transitions. Leakage inductance therefore becomes a specified interaction with magnetizing inductance, semiconductor capacitance and clamp components. Include negative and circulating currents in winding-loss calculations. GaN can support higher-frequency operation, but it does not remove core-loss, insulation, parasitic-capacitance or thermal constraints.
Compare winding ratios and polarity, inductance tolerance, leakage measurement conditions, peak-current capability, RMS loading, winding resistance, capacitance and mechanical limits. Confirm working voltage, insulation construction and the applicable safety assessment rather than relying only on a dielectric-test voltage. Qualify representative samples in the converter and control material or construction changes for both catalog and custom parts.
How to Design and Validate a Flyback Transformer
Use this procedure to connect converter requirements to a controlled, tested transformer construction.
A practical sequence for designing, measuring and qualifying a power flyback transformer.
- Define requirements and safety scope
Specify the input and bulk-voltage ranges, outputs, cross-loading, power, environment, dimensions and cooling. Establish the applicable equipment standard, working voltages and insulation barriers. Separate the overall converter efficiency target from the loss allowances used in magnetic-energy calculations.
- Choose control mode and timing
Select the controller and intended conduction mode. Establish switching-frequency behavior, duty-cycle limits, minimum timing intervals and current-limit tolerances. For DCM, reserve demagnetization and idle time; for quasi-resonant control, also accommodate the selected valley timing.
- Calculate turns ratio, inductance and currents
Choose reflected voltage by balancing switch stress, rectifier stress and demagnetization. Calculate magnetizing inductance, peak currents and winding RMS currents using equations appropriate to the waveform. Verify operating mode across line, load and tolerances, including startup and current-limit conditions.
- Select core, turns and gap
Choose a core material and geometry with sufficient cross-section, winding space and suitable bobbin construction. Establish primary turns from flux and volt-seconds, then determine the required inductance factor and gap. Check material-specific saturation, waveform-dependent core loss and gap-fringing effects.
- Design windings and estimate temperature
Select conductors using hot resistance, RMS current and AC-loss behavior. Define winding order, orientation, terminations and insulation. Balance leakage, capacitance and regulation, then estimate core and winding losses. Keep external clamp losses separate while including their contribution to the surrounding thermal environment.
- Prototype and correlate measurements
Measure turns ratio, polarity, magnetizing inductance, leakage, winding resistance and relevant capacitances under documented conditions. Check converter waveforms, overshoot, demagnetization, cross-regulation and stabilized temperatures. Adjust turns, gap, winding layout or core size and repeat the affected calculations and tests.
- Qualify and control production
Complete the applicable insulation and equipment-safety assessment, required dielectric tests and converter-level EMI evaluation. Characterize production-representative samples. Release a controlled construction drawing and acceptance specification, with traceability and change notification for materials, gap process, insulation and winding arrangement.
Further Reading
These related Passive Components Blog articles provide additional converter, modeling and insulation context.
- Flyback Converter Design and Calculation — converter-level context for translating power-stage requirements into component values.
- Flyback Transformer Explained; WE Webinar — supplementary explanation of flyback magnetics and construction considerations.
- SMPS with Flyback Transformer Explained — an additional introduction to flyback power-supply operation.
- USB PD 3.0 Flyback Transformer Optimisation — application-specific context for adapter transformer optimization.
- Flyback Transformer Modelling — further reading on representing the magnetic component in circuit analysis.
- High Voltage Transformer Safety Design Requirements – Case Study — a complementary insulation and safety-design perspective.
- Transformer Topologies in Power Converters — comparison of transformer roles in different converter families.
References
The following technical documents support the operating equations, construction guidance and standards scope cited in the text.
- John Betten, Designing a DCM Flyback Converter, Texas Instruments, SSZTCW6, 2024.
- Khaled Elshafey, Design Considerations for Flyback Transformer, Würth Elektronik, Digital WE Days presentation, 2023.
- Vincent Zhang and Ambreesh Tripathi, How to Design Flyback Converter With LM3481 Boost Controller, Texas Instruments, SNVA761A, 2016, revised 2019.
- Suchethan Swaroop Vaidyanath and John Dorosa, 15W Multi Output Offline Flyback Transformer: Design Considerations Taken to Achieve over 86% Efficiency for Industrial Appliance Applications, Würth Elektronik and Texas Instruments, ANP094, 2020.
- John Gomez, Enabling Small-Form-Factor AC/DC Adapters With the Use of Integrated GaN Technology, Texas Instruments, SLUAAP2, 2023.
- International Electrotechnical Commission, IEC 62368-1:2023 — Audio/video, Information and Communication Technology Equipment — Part 1: Safety Requirements, IEC, 2023, corrected version 2025.
- International Electrotechnical Commission, IEC 61558-2-16:2021/COR1:2023 — Corrigendum 1: Particular Requirements and Tests for Switch Mode Power Supply Units and Transformers for Switch Mode Power Supply Units for General Applications, IEC, 2023.